A wise senator once noted that democracy dies with thunderous applause. Similarly, it’s also how privacy dies, as we invite more and more smart devices willingly into our homes that are built by companies that don’t tend to have our best interests in mind. If you’re not willing to toss all of these admittedly useful devices out of the house but still want to keep an eye on what they’re doing, though, [Nick Bild] has a handy project that lets you keep an eye on them when they try to access the network.
The device is built on a Raspberry Pi that acts as a middle man for these devices on his home network. Any traffic they attempt to send gets sent through the Pi which sniffs the traffic via a Python script and is able to detect when they are accessing their cloud services. From there, the Pi sends an alert to an IoT Arduino connected to an LED which illuminates during the time in which the smart devices are active.
The build is an interesting one because many smart devices are known to listen in to day-to-day conversation even without speaking the code phrase (i.e. “Hey Google” etc.) and this is a great way to have some peace-of-mind that a device is inactive at any particular moment. However, it’s not a foolproof way of guaranteeing privacy, as plenty of devices might be accessing other services, and still other devices have even been known to ship with hidden hardware.
We’ve seen a fair number of automated wire cutting builds before, and with good reason: cutting lots of wires by hand is repetitive and carries the risk of injury. What’s common to all these automated wire cutters is a comment asking, “Yeah, but can you make it strip too?” As it turns out, yes you can.
The key to making this automated wire cutter and stripper is [Mr Innovative]’s choice of tooling, and accepting a simple compromise. (Video, embedded below.) Using just about the simplest wire strippers around — the kind with a diamond-shaped opening that adjusts to different wire gauges by how far the jaws are closed — makes it so that the tool can both cut and strip, and adapt to different wire sizes. The wire is fed from a spool to a custom attachment sitting atop a stepper motor, which looks very much like an extruder from a 3D-printer. The wire is fed through a stiff plastic tube into the jaws of the cutter. Choosing between cutting and stripping is a matter of aiming the wire for different areas on the cutter’s jaws, which is done with a hobby servo that bends the guide tube. The throw of the cutter is controlled by a stepper motor — partial closure nicks the insulation, while a full stroke cuts the wire off. The video below shows the build and the finished product in action.
Yes, the insulation bits at the end still need to be pinched off, but it’s a lot better than doing the whole job yourself. [Mr Innovative] has a knack for automating tedious manual tasks like this. Check out his label dispenser, a motor rotor maker, and thread bobbin winder.
A presentation this month by the Antique Wireless Museum brought British engineer and inventor John Sargrove (1906-1974) to our attention. If you’ve ever peeked inside old electronics from days gone by, you’ve no doubt seen point-to-point wiring and turret board construction. In the 60s and 70s these techniques eventually made way for printed circuit boards which we still use today. But Mr Sargrove was way ahead of his time, having already invented a process in the 1930s to print circuits, not just boards, onto Bakelite. After being interrupted by the war, he formed a company Electronic Circuit Making Equipment (ECME) and was building broadcast radio receivers on an impressive automatic production line.
Mr. Sargrove’s passion was making radios affordable for everyone. But to achieve this goal, he had to make large advances manufacturing technology. His technique of embedding not only circuit traces, but basic circuit elements like resistors, capacitors, and inductors directly into the substrate foresaw techniques being applied decades later in integrated circuit design. He also developed a compact vacuum tube which could be used in all circuits of a radio, called an “All-stage Valve“. Equally important was his futuristic automatic factory, which significantly reduced the number of factory workers needed to make radios from 1500 to 50. Having completed the radio design, he was also developing a television receiver using the same concepts. Unfortunately, ECME was forced into liquidation when a large order from India was cancelled upon declaration of independence in 1947.
You really must watch the video below. There are many bits and pieces of modern factory automation which we still use today, yet their implementation using 1940s techniques and technology is fascinating. Further reading links after the video. Thanks to [Mark Erdle] for the tip.
The smartphone is perhaps the signature device of our modern lives. For most of the population it is never more than an arm’s length away, it’s on your person more than any other device in your life. Smartphones are packed with all sorts of radios and ways to communicate wireless. [Amine Mansouri] built an ESP8266 based tracking device that takes advantage of this.
Most WiFi-enabled devices will send out “probe requests” frames trying to search for the SSIDs they were connected to. These packets contain the device MAC address as well as the SSIDs you’ve connected to. Using about 12 components, [Amine] laid out a small board in Eagle. By putting the ESP8266 in monitor mode, the probe frames can be logged and uploaded. The code can be updated OTA making it easy to service while in the field.
With permission from his local library, eight repeater boards were scattered throughout the building to forward the probe packets to where the tracker could pick them up. A simple web interface was built that allows the library to figure out how many people are in the library and how often they frequent the premises.
Cruise control is a common feature on automobiles, though less so in the motorcycle market. Given that continual throttle application on long rides can be a real pain in the wrist, many riders long for such a convenience. As a cheat solution, bolt-on locks that hold the throttle at a set position are available, though quality varies and generally they need to be activated by the throttle hand anyway. [Nixie] wanted a solution that would leave the right hand entirely free, and held, rather than locked, the throttle.
The device [Nixie] came up with is essentially a brake that fits inside the throttle handle and holds it in position. This is achieved with a mechanism that presses a pair of small brake shoes into the inside of the throttle, holding it from rotating back to neutral when the rider lets go. The brake is activated by a control on the left handlebar via a Bowden cable, allowing [Nixie] to activate the throttle hold on the highway and use the right hand to check pockets or simply rest.
It’s a tidy build, and [Nixie] does a great job of explaining the various design choices and the intricacies of the Bowden cable actuated mechanism. It’s anything but a one-size-fits-all build, but other enterprising machinists could certainly duplicate the design for other motorcycles without too many problems.
What makes a cyberdeck? Looking as though it came from an alternate reality version of the 1980s is a good start, but certainly isn’t required. If you’re really trying to adhere to the cyberpunk ethos, any good deck should be modular enough that it can be easily repaired and upgraded over time. In fact, if it’s not in a constant state of evolution and flux, you’ve probably done something wrong. If you can hit those goals and make it look retro-futuristic at the same time, even better.
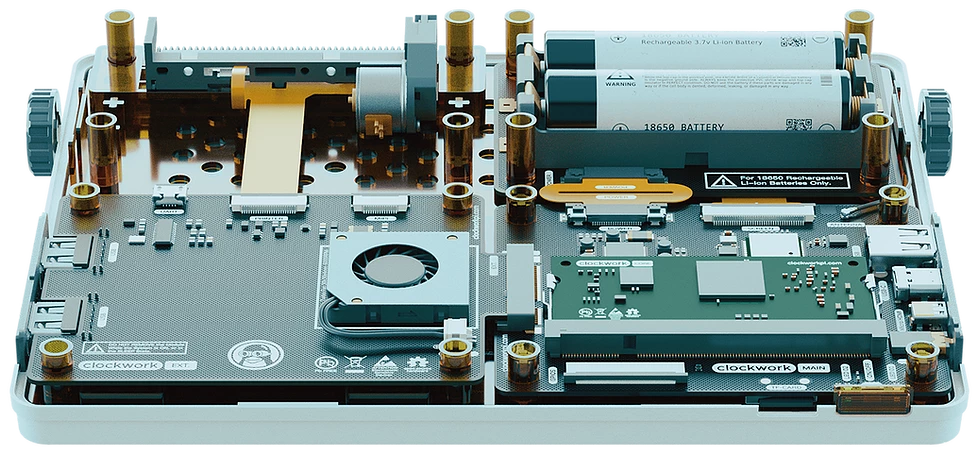
Which is why the Clockwork DevTerm is such an interesting device. It ticks off nearly every box that the custom cyberdeck builds we’ve covered over the last couple years have, while at the same time being approachable enough for a more mainstream audience. You won’t need a 3D printer, soldering iron, or hot glue gun to build your own DevTerm. Of course if you do have those tools and the skills to put them to work, then this might be the ideal platform to build on.
With a full-sized QWERTY keyboard and widescreen display, the DevTerm looks a lot like early portable computers such as the TRS-80 Model 100. But unlike the machines it draws inspiration from, the display is a 6.8 inch 1280 x 480 IPS panel, and there’s no pokey Intel 8085 chip inside. The $220 USD base model is powered by the Raspberry Pi Compute Module 3, and if you need a little more punch, there are a few higher priced options that slot in a more powerful custom module. Like the Waveshare Pi CM laptop we recently looked at, there’s sadly no support for the newer CM4; but at least the DevTerm is modular enough that it doesn’t seem out of the question that Clockwork could release a new mainboard down the line. Or perhaps somebody in the community will even do it for them.
Speaking of which, the board in the DevTerm has been designed in two pieces so that “EXT Module” side can be swapped out with custom hardware without compromising the core functionality of the system. The stock board comes with extra USB ports, a micro USB UART port for debugging, a CSI camera connector, and an interface for an included thermal printer that slots into a bay on the rear of the computer. Clockwork says they hope the community really runs wild with their own EXT boards, especially since the schematics and relevant design files for the entire system are all going to be put on GitHub and released under the GPL v3.
They say that anything that sounds too good to be true probably is, and if we’re honest, we’re getting a little of that from the DevTerm. An (CPU BLOBs aside!) open hardware portable Linux computer with this kind of modularity is basically a hacker’s dream come true, and thus far the only way to get one was to build it yourself. It’s hard to believe that Clockwork will be able to put something like this out for less than the cost of a cheap laptop without cutting some serious corners somewhere, but we’d absolutely love to be proven wrong when it’s released next year.
Vortex cooling works by injecting oxygen into the combustion chamber tangentially, just inside the nozzle of the engine, which creates a cooling, swirling vortex boundary layer along the chamber wall. The oxygen moves to the front end of the combustion chamber where it mixes with the fuel and ignites in the center. This does not protect the nozzle itself, which only lasts a few seconds before becoming unusable. However, thanks to the modular design of the test engine, only the small nozzle section had to be reprinted for every test. While this part could be manufactured using a metal 3D printer, the costs are still very high, especially at this experimental stage. The clear resin parts also allow the combustion observed and more accurate conclusions to be drawn from every test.
This engine intended to be used as a torch igniter for a much larger rocket engine. Fuel is injected into the front of the combustion chamber, where a spark plug is located to ignite the oxygen-fuel mixture. The flow of the oxygen and fuel is controlled by two servo-operated valves connected to a microcontroller, which is mounted with the engine on linear rails. This allows the test engine to move freely, and push against a load cell to measure thrust. The spark is created before the valves are opened to prevent a delayed ignition, which can blow up the engine, and getting the valve sequence and timing correct is critical. Many iterations and destroyed parts later, the [AX Technologies] team achieved successful ignition, with a clear supersonic Mach diamond pattern in the exhaust.
One of the major advantages of 3D printing is the ability to quickly test and then iterate on mechanical designs. [gzumwalt] does a lot of this, and has recently been working on various versions of a rigid chain mechanism. (Video, embedded below.)
A rigid-chain mechanism is one way of fitting a long beam into a small box. It works similar to a zipper, meshing two separate “chains” with specially teeth designed to form a rigid beam. Due to clearances between the teeth, the beam tends to be a bit floppy. [gzumwalt] made various sizes of the mechanism, and also reduced the clearances on later versions to reduce the flop. He also integrated it into a cool “snake in a basket” automaton (second video below) by adding a reversible gearbox and a binary snap-action switch.
One possible use for this type of mechanism is for autonomously assembling long structures in space, as one of the 2017 Hackaday Prize finalist projects, ZBeam, proposed.
[gzumwalt] has not made the files available for download yet, but you can keep and eye on his Instructables pages for updates. He got a number of fascinating 3D printed devices already available, like a domino laying machine or a WiFi controlled rover.
Want to buy a new phone? Have a look at the Samsung Galaxy S10 range. With their awesome design and powerful performance, it’s easy to see why these phones are such a popular option.
What does the Samsung Galaxy S10 range consist of?
The
Samsung Galaxy S10 range includes the Galaxy S10e, S10 and S10+ and all three
variations have a dual sim option.
Design
Display
To start
off with, the Galaxy S10 range features the new Infinity-O Display, which
eliminates distractions, ensuring a cinematic viewing experience. By making use
of precise laser cutting, the front-facing camera has been discreetly tucked
away in the top right-hand corner, without sacrificing photo quality.
The
Samsung Galaxy S10 and S10+ has a default resolution of Full HD+, but can be
changed to Quad HD+ in settings.
The next
generation screen on these models is HDR10+ certified and the brighter screen
makes your phone easier to use in bright daylight.
The eye
comfort display has been engineered to adjust to the light for a better view. A
unique fluid composite in the Dynamic AMOLED screen reduces harmful blue light
without changing the colour of what’s on-screen.
Photo Source – www.samsung.com
Colours
There are
various colours to choose from but may vary depending on the country and the
carrier.
Galaxy
S10e: Prism White, Prism Black, Prism Green and Canary Yellow
Galaxy
S10: Prism White, Prism Black and Prism Green
Galaxy
S10+: Prism White, Prism Black, Prism Green and Ceramic Black
Photo Source – www.samsung.com
The Fingerprint Scanner
The
Samsung Galaxy S10 range also features a fingerprint scanner that opens your
phone with a simple, natural move. The Galaxy S10e has a capacitive fingerprint
sensor on the side while the S10 and S10+ has an ultrasonic fingerprint sensor
on the screen.
Materials
The Galaxy
S10+ models with 8GB RAM with 512GB internal storage and Galaxy S10+
Performance Edition (12GB RAM with 1TB internal storage) is available in
ceramic versions.
The S10
and S10+ comes with Gorilla Glass 6 in front and Gorilla Glass 5 at the back,
while the Galaxy S10e is made with Gorilla Glass 5.
Photo Source – www.samsung.com
State-of-the-art cameras
As
mentioned before, the front camera on the S10e, S10 and S10+ is embedded in the
infinity display, which results in a larger screen and better viewing
experience.
The multi-camera system on these models uses the latest technology to enhance colours in ultra-high definition, but also reduces blur with its integrated stabiliser software.
Galaxy S10e
10MP
single front camera featuring dual pixel auto focus and UHD selfie technology.
Dual
rear camera with the cameras aligned horizontally. The lens on the left-hand
side is a 12MP wide angle lens with built-in Optical Image Stabilisation software
to reduce blurry images. The lens on the right is a 16MP ultra-wide angle lens.
Photo Source – www.samsung.com
Galaxy S10
10MP
single front camera featuring dual pixel auto focus and UHD selfie technology.
Triple
rear camera with the cameras aligned horizontally. The first camera on the left
is a 12Mp telephoto lens with a 2x zoom and OIS software to prevent photos from
blurring. In the middle you have a 12MP wide angle lens that also includes OIS
software. Then on the right you have a 16MP ultra-wide angle lens.
Photo Source – www.samsung.com
Galaxy S10+
This
model features a dual front camera. The first one on the left is a 10MP dual
pixel auto focus and UHD selfie technology and the one on the right is an 8MP
lens which gives added depth to your photos.
Triple
rear camera with the cameras aligned horizontally. The first camera on the left
is a 12Mp telephoto lens with a 2x zoom and OIS software to prevent photos from
blurring. In the middle you have a 12MP wide angle lens that also includes OIS
software. Then on the right you have a 16MP ultra-wide angle lens.
Photo Source – www.samsung.com
Performance
Photo Source – www.samsung.com
Extended battery life
The
intelligent battery learns your routine and shuts down apps when they’re not
being used. Another useful feature that extends your battery life is the
Adaptive Power Saving Mode, which is responsible for managing your battery life
based on the prediction of your day.
Effortless charging
The
Samsung Wireless Charger Duo Pad allows the S10e, S10 and S10+ to wirelessly
charge faster than previous Galaxy phones. The charging pad comes with a turbo
cooling fan that prevents your phone from overheating.
Powerful processor
The
processor ensures that you enjoy a smooth performance while preserving the
battery life. The fast performance makes it possible to play graphics-heavy
games without any hassles. These phones offer up to 8GB of RAM with up to 29%
faster CPU and 37% faster GPU.
Hybrid SIM
The dual
SIM option gives you the freedom to use two numbers, but if you’re not using an
extra SIM, you can use that slot for a microSD card instead.
Photo Source – www.samsung.com
Storage space
Galaxy S10e: 128GB with 6GB RAM or
256GB with 8GB RAM. It also has a Micro SD slot (up to 512GB).
Galaxy S10: 128GB with 8GB RAM or
512GB with 8GB RAM. It also has a Micro SD slot (up to 512GB).
Galaxy S10+: 128GB with 8GB RAM,
512GB with 8GB RAM or 1TB with 12GB RAM. It also has a Micro SD slot (up to
512GB).
Certain old computers — most frequently those using the RCA 1802 — were fond of using an early form of byte-code interpreter for programs, especially games. The interpreter, CHIP-8, was very simple to create but offered high-level features that were tedious to recreate in the native assembly language. Because there are a fair number of simple games written in CHIP-8, there are of course, emulators for it, and [River Gillis] decided to look inside the CHIP-8 byte code interpreter.
Part of the power of CHIP-8 was it only had 35 virtual instructions. That was important when you were trying to shoehorn a game and the interpreter into a very small memory. Remember, in those days 1K of memory wasn’t an unusual number, although the prototypical CHIP-8 host would have 4K.
The virtual machine has 16 8-bit data registers and a stack. Since the idea was to create games, there are features useful for that purpose. For example, drawing to the screen (by default a 64×32 pixel screen) using sprites, you get information about any collisions on the screen automatically. The instructions offered some virtualization of the display and input device — usually, a hex keypad — and also provides the ability to convert binary numbers to binary coded decimal.
So the interpreter isn’t difficult to create by design. However, [River] has to emulate a target machine, and that’s where part two will pick up. However, if you are interested in retrocomputing, retrogaming, or you just want a better understanding of how a byte-coded interpreter works, this is a fun read with lots of code examples.
Making a custom virtual computer is actually not a bad idea when you are trying to conserve memory space and make development easier. Java uses the same idea on steroids, although mostly for different reasons. P-Code was another similar system and Forth, at its core, is the same basic concept.
It would be fun to put CHIP-8 on a small computer today to make a super retro gaming console. Or scarf up an old 1802 CPU — they are still available. You can also make your own.
Photo credit: RCA Cosmac VIP by [Dave Ruske] CC BY 2.0
One thing that always provokes spirited debate around the Hackaday bunker is just how dangerous is it to use 3D printed plastic in contact with food. We mostly agree it isn’t a good thing, but we also know some people do it regularly and they don’t drop dead instantly, either. [Jakub] decided to do some testing and make some recommendations. There’s even a video explaining the results.
Unlike a lot of what we’ve read about this topic in the past, [Jakub’s] post is well-researched and does actual testing including growing bacteria cultures from cups used for milk. He starts out identifying the EU and US regulations about what you can call food-grade. There’s also recognition that while a base plastic might be safe for contact with food, there’s no way to know exactly what additives and other things are in the plastic to change its properties and color.
The chemical makeup of the plastic is just one aspect of food safety. Another important aspect is the ability for harmful pathogens to lodge in the little voids and layers of the printed object. There are also the materials used in the printer. It is possible that safe plastic can be made unsafe in a dirty hot end or by contact with something noxious in the printer.
The gaps problem led [Jakub] to an inescapable conclusion: no matter what you print with, you’ll need to coat your prints to make them actually food safe. However, the coatings are not good for things like chopping boards or things you’ll expose to heat including microwaved food or hot dishwashers. If you think SLA resin might be better, he discusses the problems with that, too.
We’ve seen plenty of prints that touch consumables, even if they might not be totally safe. We’ve even debated the safety, but we didn’t grow any cultures.
Tape may not sound that great compared to vinyl, but cassette players can be tons of fun when it comes to making your own music. See for instance the Mellotron, or this relatively easy DIY alternative, [Rich Bernett]’s Cassettone cassette player synth.
The Cassettone works by substituting the trim pot that controls the speed of the tape player’s motor with a handful of potentiometers. These are each activated with momentary buttons located underneath the wooden keys. In the video after the break, [Rich] gives a complete and detailed guide to building your own. There’s also a polished Google doc that includes a schematic and the pattern pieces for making the cabinet.
Speaking of which, isn’t the case design nice? It’s built out of craft plywood but aged with varnish and Mod-Podged bits and bobs from vintage electronics magazines. This really looks like a fun little instrument to play.
Would you rather control your tape synth with a MIDI keyboard? Just add Arduino.
It’s taken two years, but finally it’s happened. Finally a respected national mass-media outlet has asked the question Hackaday were posing shortly after the event: what evidence was there that a drone was actually present in restricted airspace?
The Guardian newspaper in the UK is the outlet looking into the mystery of the Gatwick drone. It was the worldwide story of the moment around this time back in 2018 when the London airport closed down for several days in response to a series of drone reports. The assumption being put forward was that bad actors in the drone community were to blame, but there was significant disquiet in those ranks as the police and media story simply lacked credibility to anyone with knowledge of drones. At no point could they point to evidence that held water, the couple they arrested turned out to be innocent, and eventually a police officer admitted that there might not have been a drone after all. The damage had by then been done, as Received Opinion had it that irresponsible drone enthusiasts had put lives in danger and caused huge economic damage by closing an airport for several days.
The Guardian piece paints a fascinating and detailed picture of the events surrounding the investigation, by bringing the investigative journalism resources of a national newspaper into tracing and interviewing people involved from all sides. They talk to former Gatwick employees, off-the-record police officers with knowledge of the case, a drone specialist journalist, and the drone community including some of its members with significant professional experience in the world of aviation. It talks about the slow drip-feed of freedom of information requests revealing the machinations behind the scenes and furthermore the continuing lack of tangible proof of a drone. It’s very much worth a read, and we hope it will prompt further investigation of the events without the focus being on a non-existent drone.
[Noel] was in possession of two non-working Sinclair QLs and made a series of videos about his attempts to repair and restore them. If you don’t remember the QL, it was a computer by the famous Clive Sinclair and while it was ahead of its time in some ways, it didn’t become as ubiquitous as some of its siblings or the IBM PC. It did, however, develop an almost cult-like following. You can see the trilogy of videos, below.
The machine was sophisticated for its day–after all, the QL was for quantum leap. Based on a Motorola 68008 processor running at 7.5 MHz, the QL included 128 KB of RAM and could handle up to 896 KB, a respectable amount for 1984. It even had a proprietary network interface. However, it was especially well known for having a pair of microtape drives. These were nicer than cassette tapes but perhaps not as handy as floppy disks. They were, however, cheaper to put into a computer. While there was an official operating system, it wasn’t long before most QL users switched to Minerva, a better OS.
You can really see the differences in construction techniques for 1980’s consumer electronics and today. Of course, Sinclair was known to have reasonably inexpensive gear, so that contributes, too. One interesting thing about the video: [Noel] isn’t an expert on the QL so the video documents how he approached a new problem. Even if you don’t want to fix a QL, some of the process would be useful next time you are facing an unfamiliar board.
The two computers were slightly different versions. One had an unpopulated spot for an EPROM that the newer one didn’t provide. [Noel] built a simple adapter to allow an EPROM to work with either computer. Minerva’s EPROM had a diagnostic that identifies bad chips and that was very helpful with identifying the bad RAM chips. The second video covers some of the physical restorations and the third video covers the microdrives in detail. Overall, an interesting watch.
Sinclair was pretty obsessed with the microdrives, but they never really caught on. He did have a very interesting history in the electronics marketplace.
Sometimes all that’s required to build something interesting is to put the same old pieces together differently. [Sayantan Pal] did this for the humble RGB LED matrix, creating an extra-thin version by recessing WS2812b NeoPixel LEDs inside a PCB.
The popular WS2812B is 1.6 mm in height, which happens to be the most commonly used PCB thickness. Using EasyEDA, [Sayantan] designed a 8×8 matrix with modified WS2812B footprints. A slightly undersized cutout was added to create a friction-fit for the LEDs, and the pads were moved to the back side of the panel just outside the cutout, and their assignment were flipped. The PCB is assembled face down, and all the pads are soldered by hand. Unfortunately this creates rather large solder bridges which slightly increases the overall thickness of the panel, and is probably also unsuitable for production with conventional pick-and-place assembly.
By now it’s a hardware hack that’s become common enough to be unremarkable, taking a smart light bulb or other mains switchable appliance and replacing its firmware with an open-source equivalent such as Tasmota. But what can be done when a new device is found to have a microcontroller unsupported by any open-source equivalents? If you are [Luca Dentella], you don’t throw in the towel and buy another one with a known processor, instead you reverse engineer it enough to give it a brain transplant of an ESP8266 module.
The Fcmila branded smart bulb in question was found to have a relatively unknown Chinese SoC, the Opulinks OPL1000. Since this couldn’t even raise a serial port it was more trouble than it was worth to write software for it, so instead he spent a while reverse engineering its schematic and electrical protocols, before grafting in a Wemos D1 ESP8266 board. He’s made a video about the project which you can see below the break.
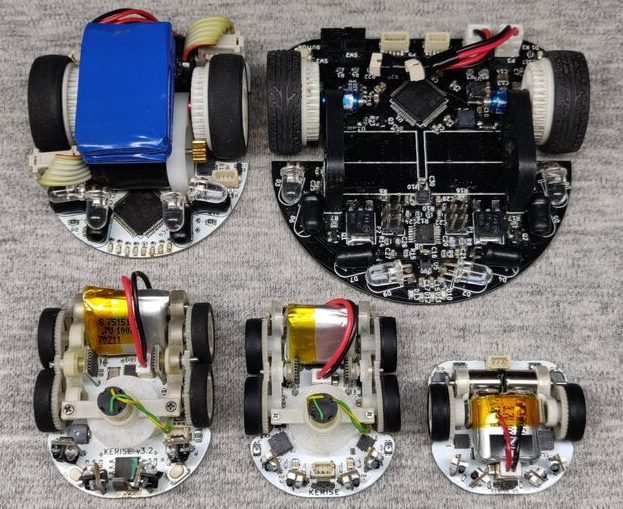
Few things fascinate a simple Hackaday writer as much as a tiny robot. We’ve been watching [Keri]’s utterly beguiling micromouse builds for a while now, but the fifth version of the KERISE series (machine translation) of ‘bots takes the design to new heights.
A family of mice v1 (largest) to v5 (smallest)
For context, micromouse is a competition where robots complete to solve mazes of varying pattern but standardized size by driving through them with no guidance or compute offboard of the robot itself. Historically the mazes were 3 meter squares composed of a 16 x 16 grid of cells, each 180mm on a side and 50mm tall, which puts bounds on the size of the robots involved.
What are the hallmarks of a [Keri] micromouse design? Well this is micromouse, so everything is pretty small. But [Keri]’s attention to detail in forming miniaturized mechanisms and 3D structures out of PCBs really stands out. They’ve been building micromouse robots since 2016, testing new design features with each iteration. Versions three and four had a wild suction fan to improve traction for faster maneuvering, but the KERISE v5 removes this to emphasize light weight and small size. The resulting vehicle is a shocking 30mm x 32mm! We’re following along through a translation to English, but we gather that [Keri] feels that there is still plenty of space on the main PCBA now that the fan is gone.
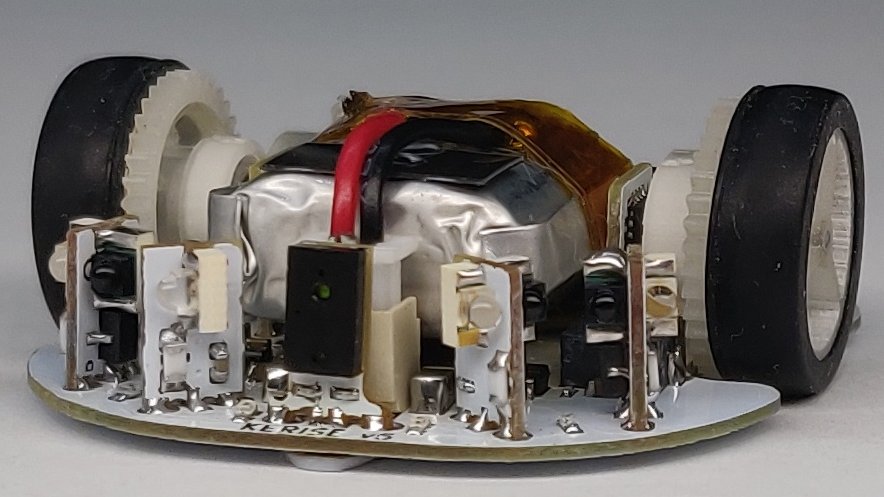
The KERISE v5 front end
The processor is a now familiar ESP32-PICO-D4, though the wireless radios are unused so far. As far as environmental sensing is concerned the v5 has an impressive compliment given its micro size. For position sensing there are custom magnetic encoders and a 3 DOF IMU. And for sensing the maze there are four side-looking IR emitter/receiver pairs and one forward-looking VL6180X laser rangefinder for measurements out to 100 or 150mm. Most of these sensors are mounted on little PCB ‘blades’ which are double sided (check out how the PCB shields the IR emitter from it’s receiver!) and soldered into slots perpendicular to the PCBA that makes up the main chassis. It goes without saying that the rest of the frame is built up of custom 3D printed parts and gearboxes.
If you’d like to build a KERISE yourself, [Keri] has what looks to be complete mechanical, electrical, and firmware sources for v1, v2, and v3 on their Github. To see the KERISE v5 dance on a spinning sheet of paper, check out the video after the break. You don’t want to miss it!
The average person’s experience with an ultraviolet (UV) wand is getting a cavity at the dentist. However, anyone with a resin-based 3d printer knows how important a UV curing system is. Often times some spots on a print need a little bit of extra UV to firm up. [Mile] has set out to create an open-source UV curing wand named Photon that is cost-effective and easy to build.
What’s interesting here is that there are dozens if not hundreds of UV curing systems ranging from $5 LED flashlights to larger industrial flood systems. [Mile] dives right in and shows the trade-offs that those cheaper modules are making as well as what the commercial systems are doing that he isn’t. [Mile’s] Photon wand tries to be energy efficient with more irradiated power while staying at a lower cost. This is done by carefully selecting the CSP LEDs instead of traditional wire-bonded and making sure the light source is properly focused and cooled. From the clean PCB and slick case, it is quite clear that [Mile] has gone the extra step to make this production-friendly. Since there are two industry-standard wavelengths that resins cure at (364nm and 405nm), the LED modules in Photon are user-replaceable.
What we love about this project is looking past what is readily available and diving deep. First understanding the drawbacks and limitations of what is there, then setting a goal and pushing through to something different. This isn’t the first UV curing tool we’ve seen recently, so it seems there is a clear need for something better that’s what is out there today.
By now you’ve no doubt heard of the sudden but not unexpected demise of the iconic Arecibo radio telescope in Puerto Rico. We have been covering the agonizing end of Arecibo from almost the moment the first cable broke in August to a eulogy, and most recently its final catastrophic collapse this week. That last article contained amazing video of the final collapse, including up-close and personal drone shots of the cable breaking. For a more in-depth analysis of the collapse, it’s hard to beat Scott Manley’s frame-by-frame analysis, which really goes into detail about what happened. Seeing the paint spalling off the cables as they stretch and distort under loads far greater than they were designed for is both terrifying and fascinating.
Exciting news from Australia as the sample return capsule from JAXA’s Hayabusa2 asteroid explorer returned safely to Earth Saturday. We covered Hayabusa2 in our roundup of extraterrestrial excavations a while back, describing how it used both a tantalum bullet and a shaped-charge penetrator to blast regolith from the surface of asteroid 162173 Ryugu. Samples of the debris were hoovered up and hermetically sealed for the long ride back to Earth, which culminated in the fiery re-entry and safe landing in the midst of the Australian outback. Planetary scientists are no doubt eager to get a look inside the capsule and analyze the precious milligrams of space dust. In the meantime, Hayabusa2, with 66 kilograms of propellant remaining, is off on an extended mission to visit more asteroids for the next eleven years or so.
The 2020 Remoticon has been wrapped up for most of a month now, but one thing we noticed was how much everyone seemed to like the Friday evening Bring-a-Hack event that was hosted on Remo. To kind of keep that meetup momentum going and to help everyone slide into the holiday season with a little more cheer, we’re putting together a “Holiday with Hackaday & Tindie” meetup on Tuesday, December 15 at noon Pacific time. The details haven’t been shared yet, but our guess is that this will certainly be a “bring-a-hack friendly” event. We’ll share more details when we get them this week, but for now, hop over to the Remo event page and reserve your spot.
On the Buzzword Bingo scorecard, “Artificial Intelligence” is a square that can almost be checked off by default these days, as companies rush to stretch the definition of the term to fit almost every product in the neverending search for market share. But even those products that actually have machine learning built into them are only as good as the data sets used to train them. That can be a problem for voice-recognition systems; while there are massive databases of utterances in just about every language, the likes of Amazon and Google aren’t too willing to share what they’ve leveraged from their smart speaker using customer base. What’s the little person to do? Perhaps the People’s Speech database will help. Part of the MLCommons project, it has 86,000 hours of speech data, mostly derived from audiobooks, a clever source indeed since the speech and the text can be easily aligned. The database also pulls audio and the corresponding text from Wikipedia and other random sources around the web. It’s a small dataset, to be sure, but it’s a start.
And finally, divers in the Baltic Sea have dredged up a bit of treasure: a Nazi Engima machine. Divers in Gelting Bay near the border of Germany and Denmark found what appeared to be an old typewriter caught in one of the abandoned fishing nets they were searching for. When they realized what it was — even crusted in 80-years-worth of corrosion and muck some keys still look like they’re brand new — they called in archaeologists to take over recovery. Gelting Bay was the scene of a mass scuttling of U-boats in the final days of World War II, so this Engima may have been pitched overboard before by a Nazi commander before pulling the plug on his boat. It’ll take years to restore, but it’ll be quite a museum piece when it’s done.
Human ears are capable of perceiving frequencies from roughly 20 Hz up to 20 kHz, at least when new. Correspondingly, our audio hardware is designed more or less to target these frequencies. However, there’s often a little extra capability at the upper edges, which [Jacek] shows can be exploited to exfiltrate data.
The hack takes advantage of the fact that most computers can run their soundcards at a sample rate of up to 48 kHz, which thanks to the Nyquist theorem means they can output frequencies up to around 24 kHz — still outside the range of human hearing. Computers and laptops often use small speaker drivers too, which are able to readily generate sound at this frequency. Through the use of a simple Linux shell script, [Jacek] is able to have a laptop output Morse code over ultrasound, and pick it up with nothing more than a laptop’s internal microphone at up to 20 meters away.
[Jacek] enjoys exploring alternative data exfiltration methods; he’s previously experimented with Ethernet leaks on the Raspberry Pi. Of course, with any airgap attack, the real challenge is often getting the remote machine to run the exfiltration script when there’s no existing remote admin access to be had. Video after the break.
Finding out you’ve got a flat tyres halfway into a long ride is a frustrating experience for a cyclist. Maintaining the
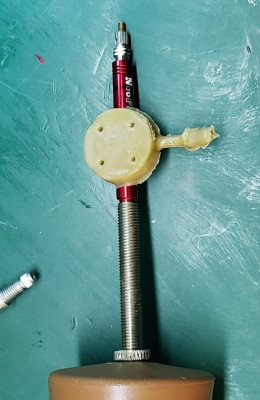
While the epoxy does a great job of sealing the PCB to the valve extension, the overmoulding process would likely be key to producing a product with shelf-quality fit and finish. This test run was done with 3D printed ABS moulds.
The device consists of an ultra low power microcontroller from Texas Instruments, paired with a pressure sensor. Set up for Near Field Communication, or NFC, it’s designed to be powered by the smartphone that queries the microcontroller for a reading. We featured a prototype back in 2015 which required mounting the device within the inner tube of the tyre itself. However, this required invasive installation and the devices tended to wear out over time due to flex damaging the delicate copper coil antenna.
The new design consists of the same microcontroller hardware, but mounted in a modified valve extension that fits to the fill valve of the bicycle tyre. The PCB is directly epoxied on to the valve extension, ensuring air can’t leak out over time. The assembly is then overmoulded in an injection moulding process to provide further sealing and protection against the elements. This should help immensely in rough-and-tumble mountain biking applications.
The new device provides a simple screw-on solution for tire pressure monitoring that’s set and forget — no batteries required. [CaptMcAllister] is currently investigating options for a production run, and given the simple design, we imagine it couldn’t be too hard to rattle off a few hundred or thousand units. We could imagine it would also pair well with a microcontroller, NFC reader, and a display setup on the handlebars to give live readings where required. We look forward in earnest to seeing where this project goes next!
When we first saw [Barqunics’] design for a self-stabilizing spoon for people suffering from Parkinson’s disease, we wondered how well something like that could work. But take a look at the video below and you’ll see this does a fine job of responding to the user’s hand movements and keeping the spoon perfectly level through a wide range of motion.
There’s at least one commercial product that attempts to stabilize a spoon in the same way so that people suffering from that affliction can retain a measure of independence. This shows that you don’t need injection molding and factory made boards to prove the concept. An MPU6050 provides sensor information and two servo motors control the spoon using PID control.
PID — short for proportional, integral, derivative — is a way to adjust something to a desired point. For example, consider trying to heat a cup of water to 95 °C. If you simply turn the heater on full blast until you get to 95 °C, the water will actually get hotter because you’ll overshoot. Using PID, the amount of heating provided will depend on how far off you are now (proportional), how far off you’ve been over the long term (integral), and how much change you’ve effected recently (derivative). The same algorithm works for spoon-balancing and many other types of controls.
Sometimes when a piece of electronics lands on the bench, you find that its chips have their markings sanded off. The manufacturer is trying to make the task of the reverse engineer less easy, thus protecting their market. [Maurizio Butti] found an unexpected one in an electronic switch designed for remote control systems, it had the simple job of listening to the PWM signal from a receiver in a model aircraft or similar and opening or closing a FET.
From previous experience he suspected it might be a microcontroller from STC based on the location of power, ground, Rx, and Tx pins. This 8051-compatible device could be readily reprogrammed, so he has able to create his own firmware for it. He’s published the code and it’s pretty simple, as it simply replicates the original. He acknowledges that this might seem odd, but makes the point that it is left open for future upgrades such as for example repeatedly cycling the output as in a flashing light.
We don’t see so much of the STC chips here aside from one of their earlier offerings, but the 8051 core features here more regularly as it’s found in Nordic’s NRF24 series of wireless-capable chips.
Chain link fences are woven with a mechanism that is almost hypnotic to watch, so [Levsha] decided to build his own tiny hand-crank tabletop version to make tiny copper wire fences.
Chain link consist of a series of wires bent and woven in a zigzag pattern. The zigzag bends are made by winding the wire around a rotating flat plate inside a stationary tube with a spiral slot in the side to keep the spacing of the bends consistent. [Levsha]’s version is roughly 1/10 scale of the real thing, and only does the bending and winding parts. Linking the bent wire together is up to the operator. All the components were machined on a lathe and CNC router, and beautifully finished and assembled on a wood base. The hardest part was the tube with the spiral slot, which took a few attempts to get right. [Levsha] initially tried to use steel wire, but it was too stiff and caused the winding mechanism to lock up. 0.4 mm copper wire turned out to be the best choice.
Although there is no practical use for this device that we can see, the craftsmanship is excellent, and it is one of those videos that reminds us how badly we want some machine tools.